LLMs · Scene graphs · PDDL In progress
LLM-guided common-sense planning
An LLM supplies the common sense; a symbolic planner keeps the plan correct.
about
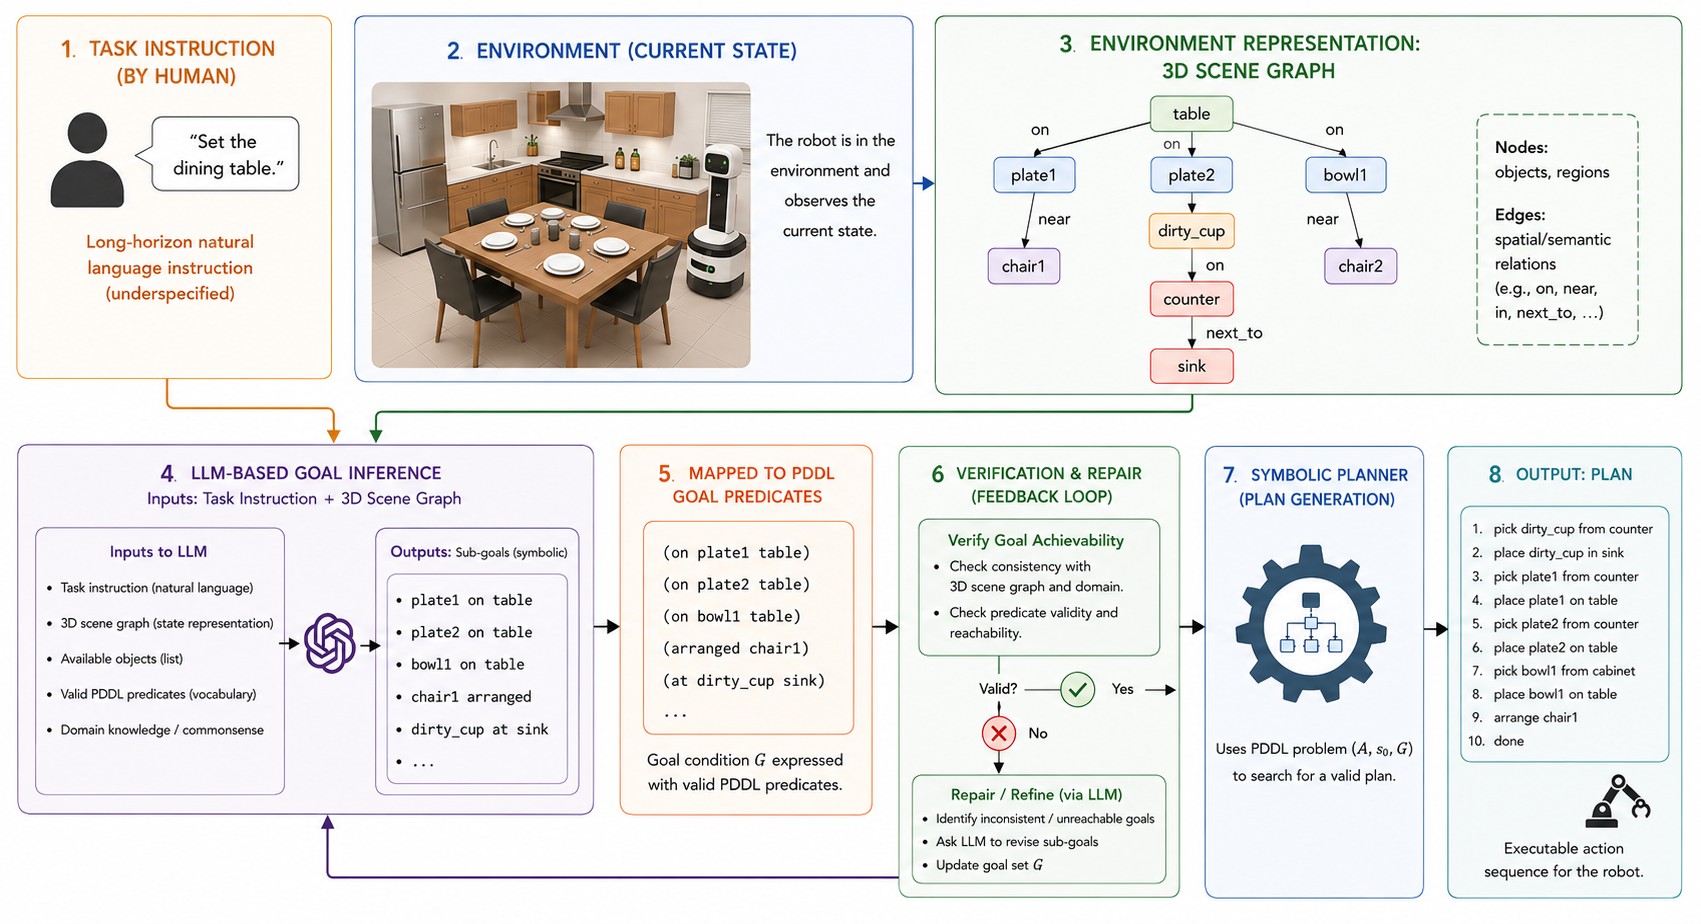
Instructions like “set the dining table” name an activity but never state the goal. Given the scene as a 3D scene graph, an LLM infers grounded PDDL goal predicates, which are checked against the planning domain and repaired through a feedback loop before a symbolic planner produces the plan.
The LLM supplies the common sense; the planner keeps the plan correct. Evaluation is planned in a simulated kitchen–dining domain with BEHAVIOR-1K tasks, followed by a real-robot demo.
LLMs · Scene graphs · PDDL · Fast Downward